TRON 2 · DOCUMENTATION
Specifications
Excerpted from the supplied English User Manual v1.4. Chinese editorial corrections and later confirmations may not be synchronized. Check the Chinese reference where the two differ.
Configuration: dual-arm details apply only to dual-arm/mobile dual-arm robots. Older instructions differ in power timing, light names and homing motion; check the operational guidance and version notes on this page.
1.2 Product Specifications
| Parameter Category | Parameter Item | TRON 2 EDU Version | TRON 2 Standard Version | Notes |
| "–" = Not available, "o" = Optional, "✓" = Standard Version | ||||
| Mechanical Parameters | Material | Aluminum alloy, plastic | Aluminum alloy, plastic | |
| Degrees of Freedom | Single arm: 7 DOF; single leg: 5 DOF; head: 2 DOF | Single arm: 7 DOF; single leg: 5 DOF; head: 2 DOF | ||
| Dimensions | Dual-Arms | - Shoulder width: 447 mm - Arm length: 730 mm (without gripper) | - Shoulder width: 447 mm - Arm length: 730 mm (without gripper) |
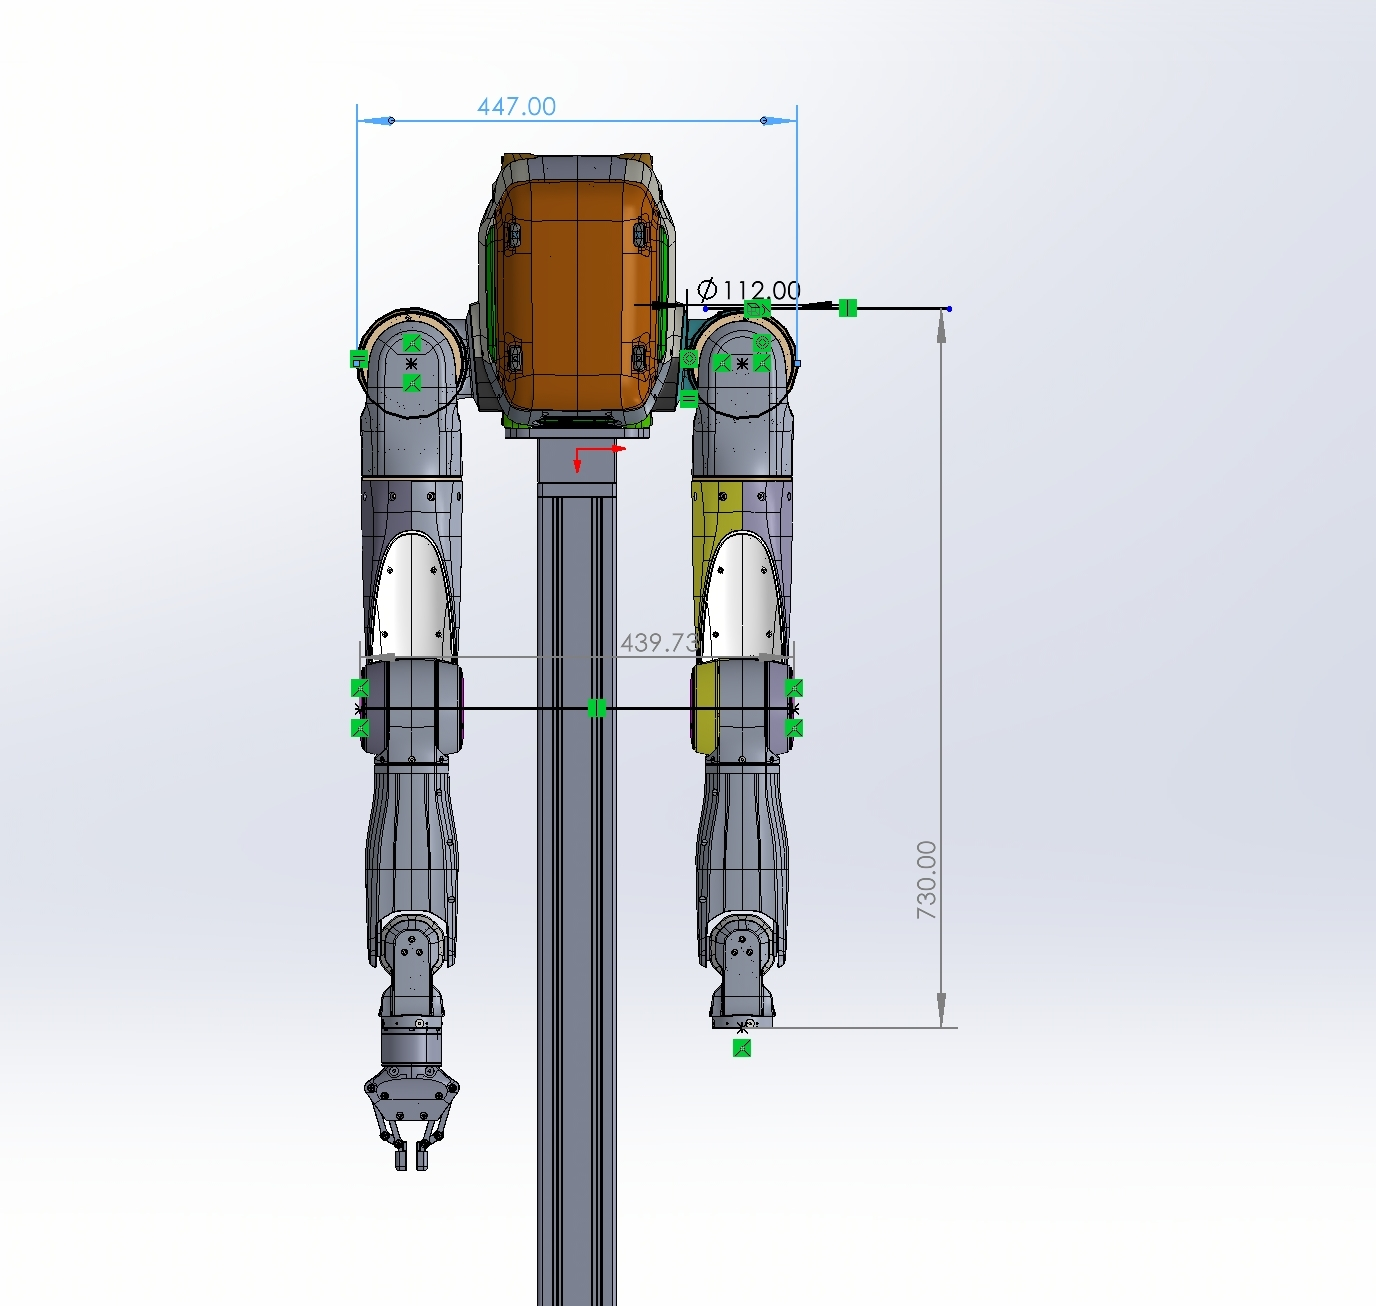
|
| Sole | - Overall width: 453 mm - Standing height: 987 mm | - Overall width: 453 mm - Standing height: 987 mm |
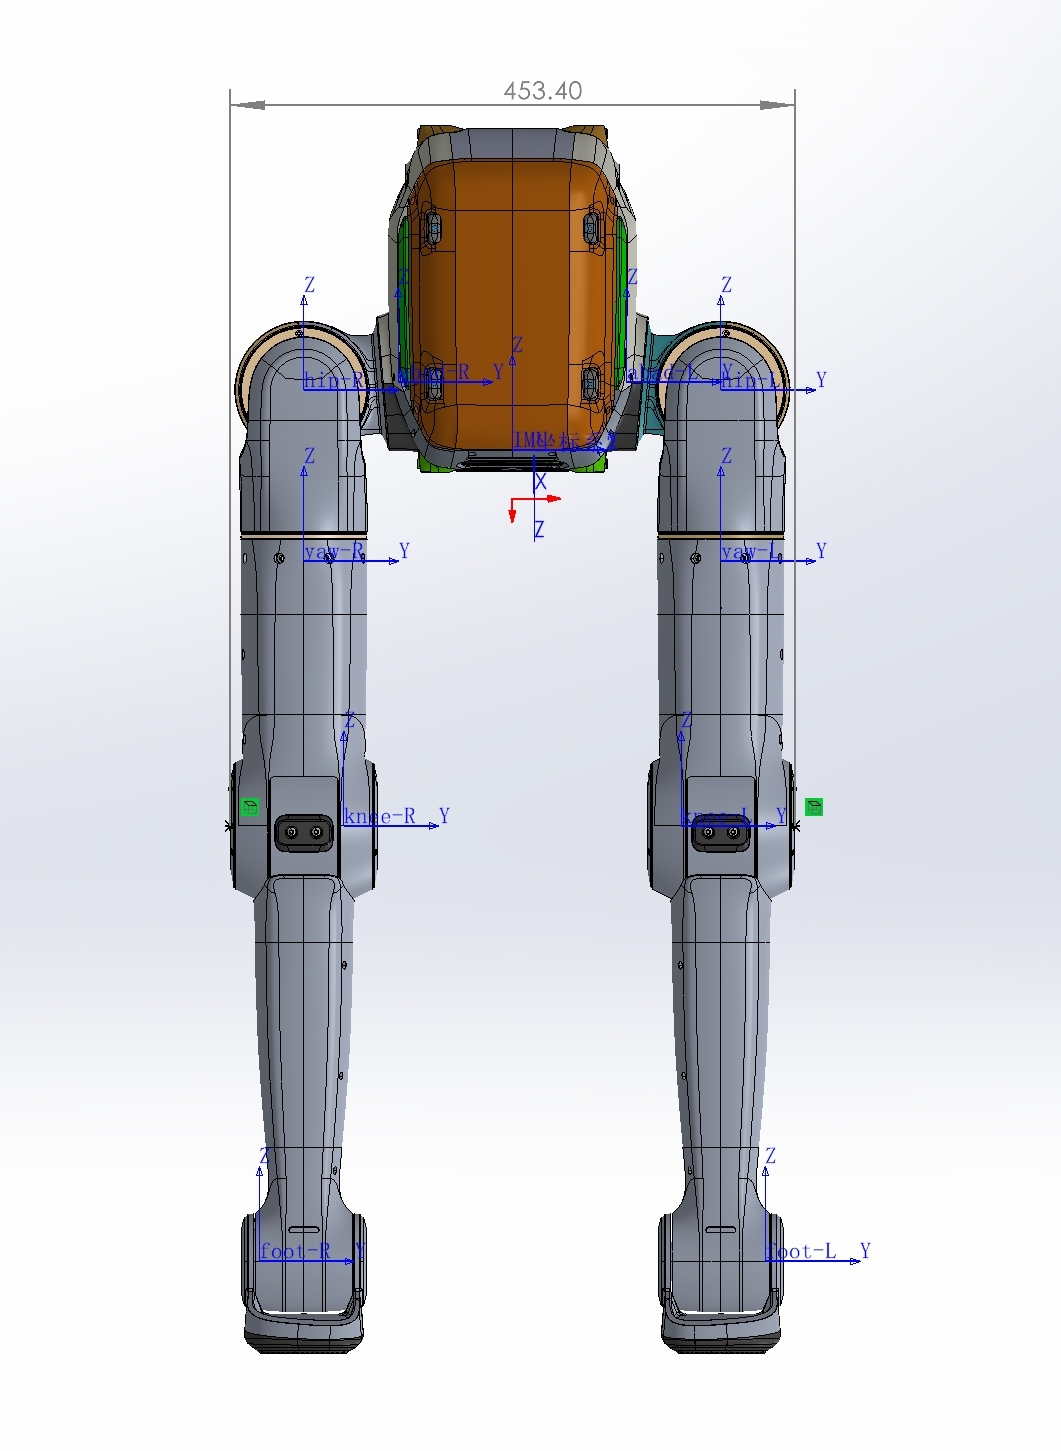
| |
| Wheeled-legs | - Overall width: 478 mm - Standing height: 1015 mm | - Overall width: 478 mm - Standing height: 1015 mm |
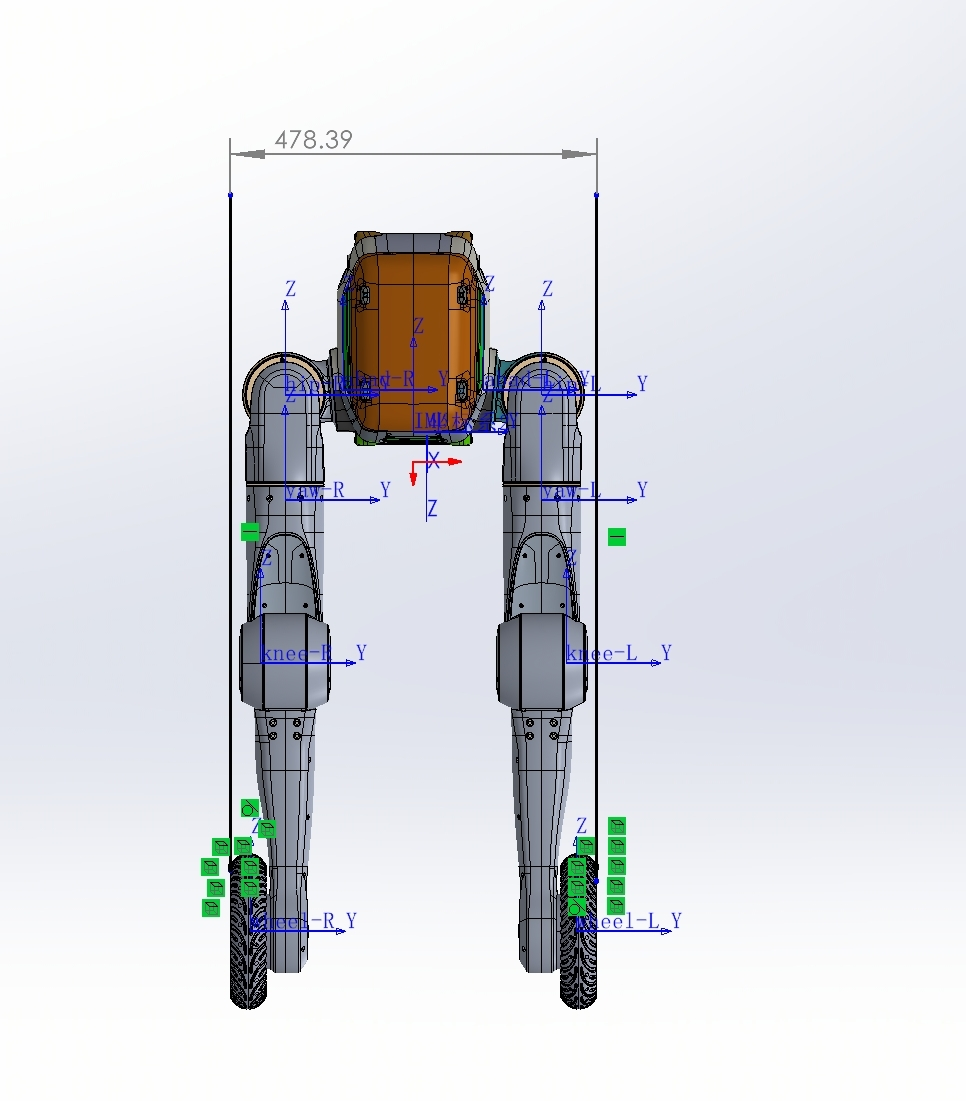
| |
| Top Expansion Area | Width: 146 mm; depth: 170 mm | Width: 146 mm; depth: 170 mm | ||
| Functions | Secondary Development | √ | — | |
| Sole/Wheeled Control Functions | Four-directional Movement, Turning, Static Standing, Squatting Down In-place, Robot Height Adjustment, Stand Up After a Fall, and Ground Clearance Detection | Four-direction movement, turning, static standing, height adjustment (squat/stand), fall recovery, off-ground detection | ||
| Dual-Arm Teleoperation Method | VR device (PICO 4 Ultra) | — | ||
| Data Collection and Local Storage | √ | — | ||
| Dual-Arm Safety Boundary Protection | √ | — | ||
| Dual-Arm Configuration | Maximum End Effector Load | Maximum: 5kg per arm; Extended: 3kg per arm | Maximum: 5kg per arm; Extended: 3kg per arm | |
| Maximum End-Effector Speed | 5m/s | 5m/s | ||
| Maximum End-Effector Acceleration | 36m/s² | 36m/s² | ||
| Repeat Positioning Accuracy | ± 0.5mm | ± 0.5mm | ||
| Teleoperation Delay | 100ms | 100ms | ||
| End-Effector Type | Gripper \ Dexterous hand | Gripper \ Dexterous hand | ||
| Gripper Performance | Gripping Force: 20N Maximum; Gripping Width: 85mm | Gripping Force: 20N Maximum; Gripping Width: 85mm | ||
| Sole/Wheeled Configuration | Maximum Movement Speed | Sole: 2-3 m/s; wheeled: 3-5 m/s | Sole: 2-3 m/s; wheeled: 3-5 m/s | |
| Maximum Climbing Slope | Sole: 15°; wheeled: 30° | Sole: 15°; wheeled: 30° | ||
| Maximum Step Height | 20cm | 20cm | ||
| Maximum Load Capacity | 30kg for flat ground walking; 20kg for stair climbing | 30kg for flat ground walking; 20kg for stair climbing | ||
| Electrical Parameters | Battery Output Voltage | 46.8V | 46.8V | |
| Maximum Battery Power | 2800W | 2800W | ||
| Support for Battery Replacement | √ | √ | ||
| Battery Type | Ternary lithium battery | Ternary lithium battery | ||
| Battery Capacity | 9Ah | 9Ah | ||
| Charging Power | 542W | 542W | ||
| Charging Input Voltage/Current | 100~240V/8A | 100~240V/8A | ||
| Charging Output Voltage/Current | 54.275V/10A | 54.275V/10A | ||
| Charging Time | 20-80% Charge: 30min ; 20-100% Charge: 54min | 20-80% Charge: 30min ; 20-100% Charge: 54min | ||
| Sensor Configuration | Waist RGBD Camera | √ | √ | |
| IMU(Inertial Measurement Unit) | √ | √ | ||
| Head RGBD Camera | ✓ (only for Dual-Arms / Mobile Dual-Arms ) | — | ||
| Wrist RGBD Camera | ✓ (only for Dual-Arms / Mobile Dual-Arms) | — | ||
| Communication Interfaces | Ethernet Port | √ (1 port) | √ (1 port) | |
| USB 3.0 Port | √ (1 port) | √ (1 port) | ||
| EtherCAT Port | √ (2 port) | √ (2 port) | ||
| RS485 Port | √ (1 port) | √ (1 port) | ||
| Peripheral Charging Interfaces | 24 V Power Output Port | √ (2 port) | √ (2 port) | |
| 48 V Power Output Port | √ (1 port) | √ (1 port) | ||
| Power Supply Port | External Power Supply Port | √ (1 port) | √ (1 port) | |
| Developer Expansion Module | CPU | Intel Core Ultra | — | |
| Storage Capacity | 2TB | — | ||
| Interfaces | 3 x ETH ports, 3 x USB 3.0, 1 x 24 V input power, 1 x 12 V output power | — | ||
| Software Compatibility and Developer Tools | SDK | √ | — | |
| Robot Management Platform | √ | √ | ||
| Data Platform | √ | — | ||
| Simulation Platform | √ | — | ||
| Software Compatibility | Compatible with Python, C++ development environments; Supports ROS1/ROS2 systems | — | ||
Dual-arm configuration details · 1.2 Product Specifications
| Parameter Category | Parameter | TRON 2 EDU Version | TRON 2 Standard Version | Notes |
|---|---|---|---|---|
| — indicates not available, o indicates optional, and ✓ indicates standard equipment. | ||||
| Mechanical Parameters | Material | Aluminum alloy, plastic | Aluminum alloy, plastic | |
| Degrees of Freedom | 7 DOF per arm 2 DOF for the head | 7 DOF per arm 2 DOF for the head | ||
| Dimensions | Dual Arms | · Shoulder width: 447 mm · Arm length: 730 mm (excluding grippers) | · Shoulder width: 447 mm · Arm length: 730 mm (excluding grippers) | |
| Top Expansion Area | Width: 146 mm; depth: 170 mm | Width: 146 mm; depth: 170 mm | ||
| Functions | Secondary Development | ✔ | — | |
| Dual-Arm Teleoperation Method | VR device (PICO 4 Ultra) | — | ||
| Data Collection and Local Storage | ✔ | — | ||
| Dual-Arm Safety Boundary Protection | ✔ | — | ||
| Dual-Arms Configuration Performance | Maximum End Effector Load | 5 kg per arm with the arm fully extended 3 kg rated | 5 kg per arm with the arm fully extended 3 kg rated | |
| Maximum End-Effector Speed | 5 m/s | 5 m/s | ||
| Maximum End-Effector Acceleration | 36 m/s² | 36 m/s² | ||
| Repeat Positioning Accuracy | ±0.5 mm | ±0.5 mm | ||
| Teleoperation Delay | 100 ms | 100 ms | ||
| End-Effector Type | Gripper, Dexterous Hand | Gripper, Dexterous Hand | ||
| Gripper Performance | Gripping Force: 20 N Maximum Gripper Stroke: 85 mm | Gripping Force: 20 N Maximum Gripper Stroke: 85 mm | ||
| Electrical Parameters | Battery Output Voltage | 46.8 V | 46.8 V | |
| Maximum Battery Power | 2800 W | 2800 W | ||
| Support for Battery Replacement | ✔ | ✔ | ||
| Battery Type | Ternary lithium battery | Ternary lithium battery | ||
| Battery Capacity | 9 Ah | 9 Ah | ||
| Charging Power | 542 W | 542 W | ||
| Charging Input Voltage/Current | 100~240 V/8 A | 100~240 V/8 A | ||
| Charging Output Voltage/Current | 54.275 V/10 A | 54.275 V/10 A | ||
| Charging Time | - 20–80%: 30 min; - 20–100%: 54 min | - 20–80%: 30 min; - 20–100%: 54 min | ||
| Sensor Configuration | Waist RGBD Camera | √ | √ | |
| IMU | √ | √ | ||
| Head RGBD Camera | Standard on the Dual-Arms Configuration | — | ||
| Wrist RGBD Camera | Standard on the Dual-Arms Configuration | — | ||
| Communication Interfaces | Ethernet Port | ✓ (1 port) | ✓ (1 port) | |
| USB 3.0 Port | ✓ (1 port) | ✓ (1 port) | ||
| EtherCAT Port | ✓ (2 ports) | ✓ (2 ports) | ||
| RS485 Port | ✓ (1 port) | ✓ (1 port) | ||
| Peripheral Charging Interfaces | 24 V Power Output Port | ✓ (2 ports) | ✓ (2 ports) | |
| 48 V Power Output Port | ✓ (1 port) | ✓ (1 port) | ||
| Power Supply Interface | External Power Supply Port | ✓ (1 port) | ✓ (1 port) | |
| Developer Expansion Module | Architecture | Intel Core Ultra | — | |
| Storage | 2 TB | — | ||
| Interfaces | 3 × ETH ports; 3 × USB 3.0 ports; 1 × 24 V power input; 1 × 12 V power output | — | ||
| Software Compatibility and Developer Tools | SDK | √ | — | |
| Robot Management Platform | √ | √ | ||
| Data Platform | ✔ | — | ||
| VR Teleoperation Software | ✔ | — | ||
| Simulation Platform | ✔ | — | ||
| Software Compatibility | Compatible with Python and C++ development environments; compatible with ROS 1/ROS 2 | — | ||
NEXTExpansion kits